
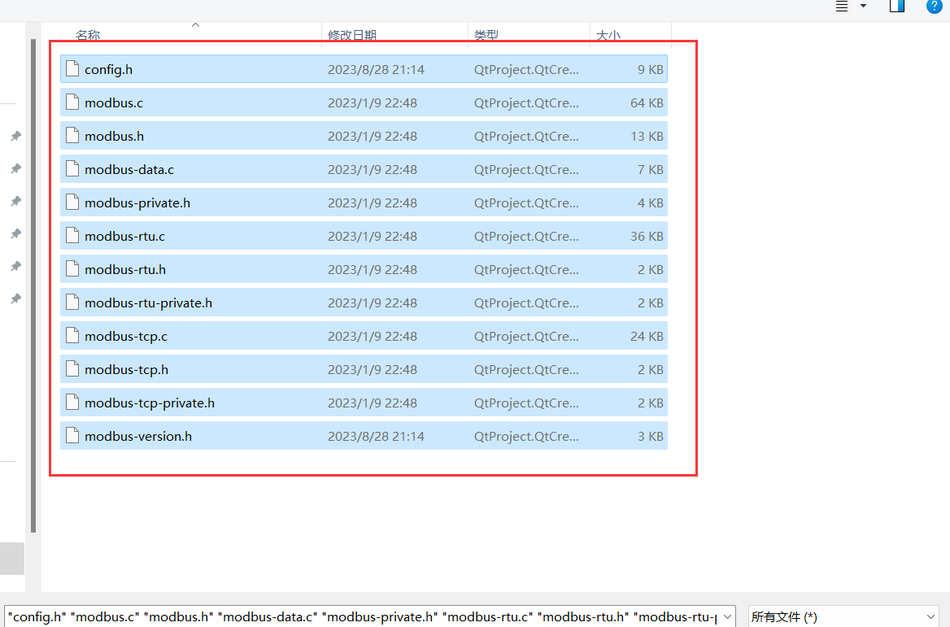
개 요
lib mod bus 는 전통적인 RS - 23 2, RS - 42 2, RS - 48 5 및 이 더 넷 장치를 지원 하는 빠르고 이 식 가능한 Mod bus 라이 브 러 리 입니다 .
설치
Linux、MacOS、FreeBSD、WIN32等可直接経由包管理器インストール
lib mod bus 공식 웹 사이트 다운로드 : www . example . com https://libmodbus.org/releases/libmodbus-3.1.7.tar.gz
/ / 압 축 해 제 디 렉 토 리로 이동 합니다 .
cd lib mod bus - 3. 1. 7
/ / 구성 컴 파 일 옵션 (예 : AR M , -- build 은 시스템 아 키 텍 처 , -- host 는 컴 파 일 시스템 도구 체 인 , -- pre fix 는 출 력 디 렉 토 리 , 옵션 은 모두 선택 적)
./ configure --build=i686 --host=arm-linux --enable-static --prefix=
/ / 컴 파 일 설치
make make 설치 하기&&
예 제
R TU 마스터
# include st dio . h<>
#include >
#include >
# include " mod bus . h "

int main (vo id)
{
    int i = 0 ;
    int reg s = 0 ;
    mod bus _ t * c t x = N ULL ;
    uint16_t tab_reg

    / / Open port : 포 트 , 보 트 속도 , 체크 비트 , 데이터 비트 , 중지 비트
    c t x = mod bus _ new _ r tu ("/ dev / tt y US B 0 ", 96 00, ' N ', 8, 1);
    / / 슬 레이 브 주소 설정
    mod bus _ set _ slave (ct x , 1);
    / / 직 렬 포 트 모 드 설정 (선 택 사항)
    mod bus _ r tu _ set _ serial _ mode (ct x , MO DB US _ R TU _ RS 48 5) ;
    / / R TS 설정 (선 택 사항)
    mod bus _ r tu _ set _ r ts (ct x , MO DB US _ R TU _ R TS _ UP);
    / / 연결 만들기
    if (mod bus _ connect (ct x) == - 1) {
        f print f (st der r , " 연 결 실패 : % s \ n ", mod bus _ str er ror (err no));
        mod bus _ free (ct x)
        return - 1;
    }
    / / 응답 지 연 설정 (선 택 사항)
    mod bus _ set _ response _ time out (ct x , 0, 100 0000);

    while (1)
    {
        mem set (tab _ reg , 0, size of (tab _ reg));
        읽기 레 지 스터 설정 : 레 지 스터 주소 , 수 량 , 데이터 버 퍼
        reg s = mod bus _ read _ register s (ct x , 0, 20, tab _ reg);
        if (r c == - 1) {
           f print f (st der r , " % s \ n ", mod bus _ str er ror (err no));
           계속 ;
        }
        printf("
        for (i = 0; i
        {
            printf("
        }
        print f ( " \ n ");
        잠 들 다 (1)
    }
}- R TU - Master 프로세 스 요 약 :
- mod bus 포인 터 초기 화
- 슬 레이 브 스테 이션 ID 설정
- 연결 설정
- 읽기 유지 레 지 스터 / 입력 레 지 스터 / 이 산 입력 / 코 일 입력
- 단일 레 지 스터 / 다 중 레 지 스터 / 다 중 비트 데이터 쓰 기
- 연결 닫 기
R TU 슬 레이 브
# include st dio . h<>
#include >
#include >
#include >
#include >
# include " mod bus . h "

int main (vo id)
{
    int i = 0 ;
    int r c = 0 ;
    mod bus _ t * c t x = N ULL ;
    mod bus _ mapp ing _ t * mb _ mapp ing = N ull ;
    uint8_t query

    / / Open port : 포 트 , 보 트 속도 , 체크 비트 , 데이터 비트 , 중지 비트
    c t x = mod bus _ new _ r tu ("/ dev / tt y US B 0 ", 96 00, ' N ', 8, 1);
    / / 슬 레이 브 주소 설정
    mod bus _ set _ slave (ct x , 1);
    S erial Mode 설정
    mod bus _ r tu _ set _ serial _ mode (ct x , MO DB US _ R TU _ RS 48 5)
    R TS 설정
    / / mod bus _ r tu _ set _ r ts (ct x , MO DB US _ R TU _ R TS _ UP);
    / / 연결 만들기
    if (mod bus _ connect (ct x) == - 1) {
        f print f (st der r , " 연 결 실패 : % s \ n ", mod bus _ str er ror(errno));
        modbus_free(ctx);
        return -1;
    }
    mb_mapping = modbus_mapping_new(MODBUS_MAX_READ_BITS, 0,
                                    MODBUS_MAX_READ_REGISTERS, 0);
    if (mb_mapping == NULL) {
        fprintf(stderr, "Failed to allocate the mapping: %s\n",
                modbus_strerror(errno));
        modbus_free(ctx);
        return -1;
    }

   //初期化几1つのレジスタ
   mb_mapping->tab_registers[0] = 1;
   mb_mapping->tab_registers[1] = 2;
   mb_mapping->tab_registers[2] = 3;
   mb_mapping->tab_registers[3] = 4;
   mb_mapping->tab_registers[4] = 5;
   mb_mapping->tab_registers[5] = 6;

    while (1)
    {
        memset(query, 0, sizeof(query));
        rc = modbus_receive(ctx, query);
        if (rc > 0) {
            modbus_reply(ctx, query, rc, mb_mapping);
        } else if (rc  == -1) {
            //Connection closed by the client or error
            break;
        }
    }

    printf("Quit the loop: %s\n", modbus_strerror(errno));

    modbus_mapping_free(mb_mapping);
    if (s != -1) {
        close(s);
    }
    modbus_close(ctx);
    modbus_free(ctx);
}
RTU-Slave流程总结:
- 初期化 modbus 指针;
- 設定スレーブID;
- modbus_mapping_new初期化レジスタ,戻る一个modbus_mapping_t 指针;
- 建立连接;
- 调用 modbus_receive 函数判断シリアルポート的受信データ,负责受信処理及回复。
TCP master
#include <stdio.h>
#include <unistd.h>
#include <stdlib.h>
#include <error.h>
#include <memory.h>
#include <sys/socket.h>
#include "modbus.h"

void main(void)
{
    int i;
    int regs = 0;
    int num = 0;
    modbus_t *ctx = NULL;
    uint16_t tab_reg[64] = {0};

    ctx = modbus_new_tcp("127.0.0.1",8000);
    modbus_set_slave(ctx, 1);
    modbus_connect(ctx);
    modbus_set_response_timeout(ctx, 0, 1000000);

    while (1)
    {
        memset(tab_reg, 0, sizeof(tab_reg));
        regs = modbus_read_registers(ctx, 0, 20, tab_reg);
        printf("[%4d][read num = %d]", num++, regs);
        for (i = 0; i < 20; i++)
        {
            printf("<%#x>", tab_reg[i]);
        }
        printf("\n");
        sleep(1);
    }

    modbus_close(ctx);
    modbus_free(ctx);
}
TCP slave
#include <stdio.h>
#include <unistd.h>
#include <stdlib.h>
#include <error.h>
#include <memory.h>
#include <sys/socket.h>
#include "modbus.h"

int main(void)
{
    int i = 0;
    int rc = 0;
    modbus_t *ctx = NULL;
    modbus_mapping_t *mb_mapping = NULL;
    uint8_t query[MODBUS_TCP_MAX_ADU_LENGTH];

    //打开ポート: ip, port
    ctx = modbus_new_tcp("127.0.0.1", 8000);
    //設定スレーブアドレス
    modbus_set_slave(ctx, 1);
    //建立连接
    if (modbus_connect(ctx) == -1) {
        fprintf(stderr, "Connexion failed: %s\n", modbus_strerror(errno));
        modbus_free(ctx);
        return -1;
    }
    mb_mapping = modbus_mapping_new(MODBUS_MAX_READ_BITS, 0,
                                    MODBUS_MAX_READ_REGISTERS, 0);
    if (mb_mapping == NULL) {
        fprintf(stderr, "Failed to allocate the mapping: %s\n",
                modbus_strerror(errno));
        modbus_free(ctx);
        return -1;
    }

   //初期化几1つのレジスタ
   mb_mapping->tab_registers[0] = 1;
   mb_mapping->tab_registers[1] = 2;
   mb_mapping->tab_registers[2] = 3;
   mb_mapping->tab_registers[3] = 4;
   mb_mapping-
   mb_mapping-

    while (1)
    {
        mem set (qu ery , 0, size of (qu ery))
        r c = mod bus _ receive (ct x , quer y)
        if (rc
            mod bus _ reply (ct x , quer y , r c , mb _ mapp ing)
        } else if (r c == - 1) {
            클 라이언 트에 의해 연결 이 닫 혔 거나 오류 가 발생 했습니다 .
            break ; break ;
        }
    }

    print f (" Qu it the loop : % s \ n ", mod bus _ str er ror (err no));

    mod bus _ mapp ing _ free (mb _ mapp ing);
    if (s ! =) - 1) {
        닫 기 (s);
    }
    mod bus _ close (ct x);
    mod bus _ free (ct x)
}

第一次接觸,善用資源學習
不知道怎么用的,来学习一下。
试试看,能否正常使用。
值得学习
值得学习参照.
值得学习参照